B2XKLAIM
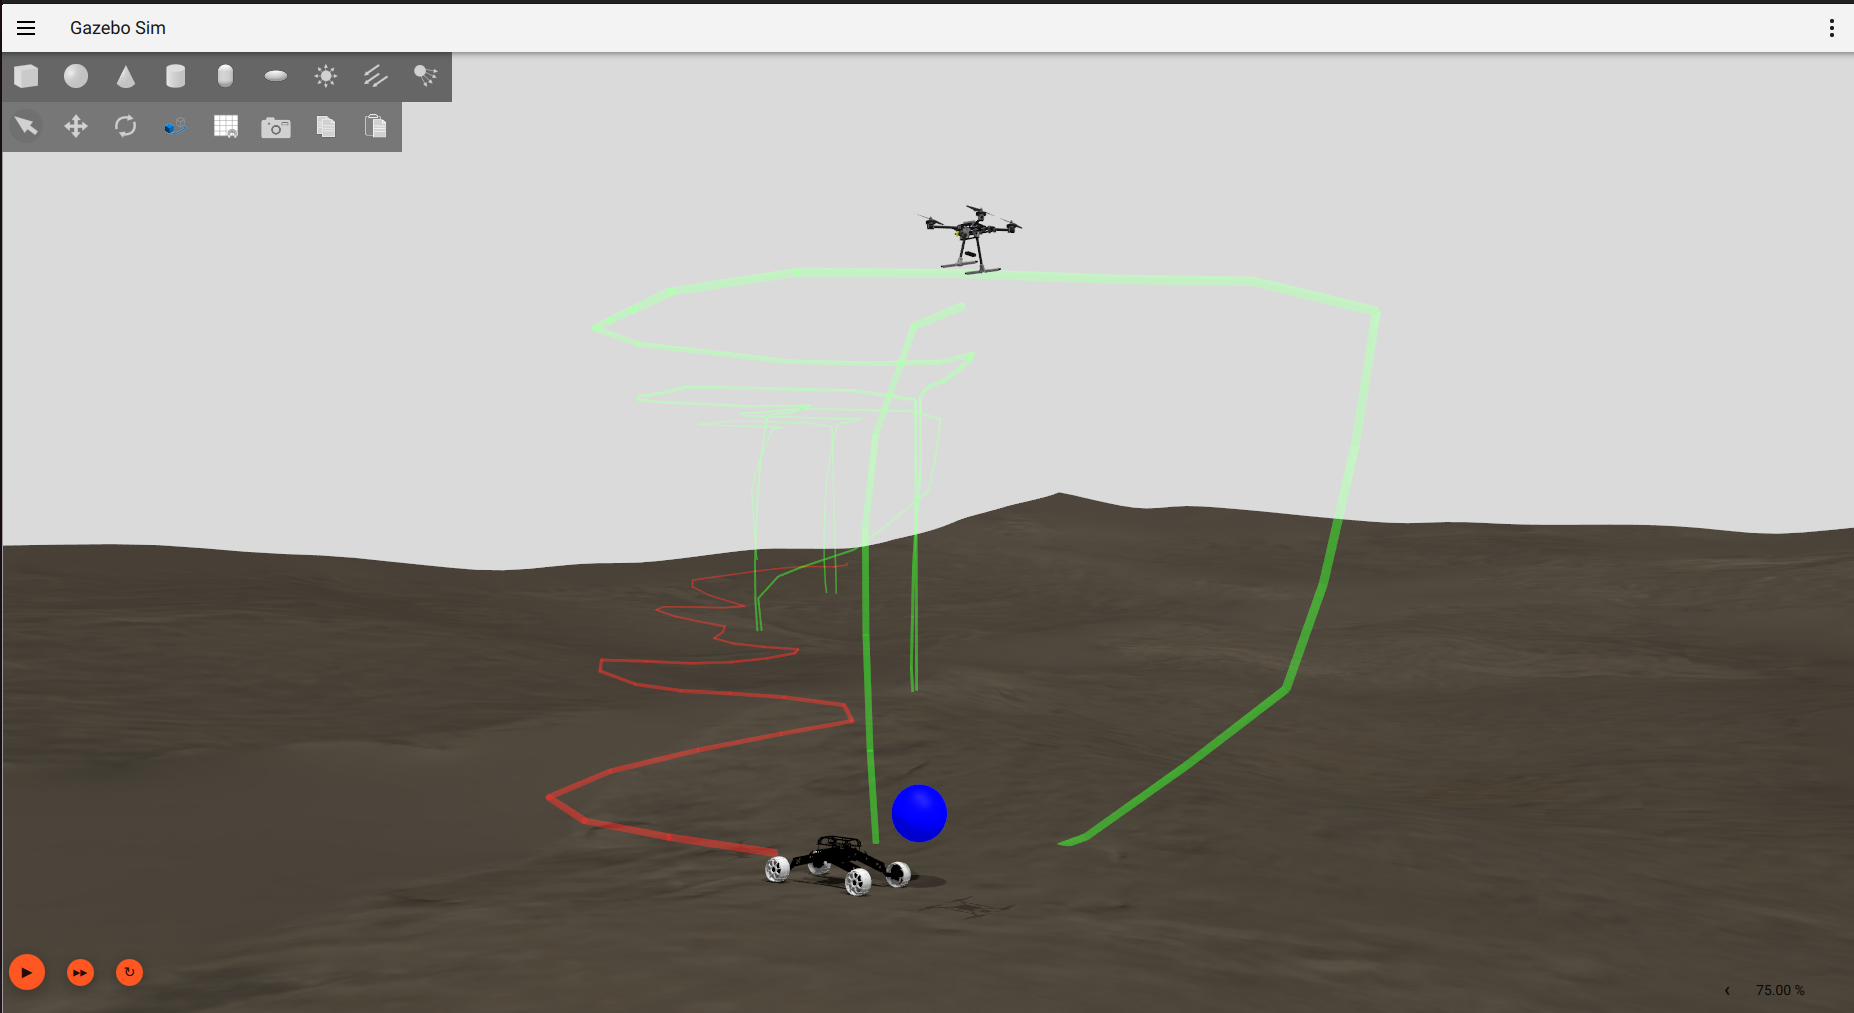
A web application where you upload BPMN 2.0 models, generate executable X-Klaim code using tuple space communication, and deploy directly on ROS-based multi-robot systems.
04 / PORTFOLIO
Research and engineering projects spanning simulation, multi-robot coordination, and full-stack platforms.
A web application where you upload BPMN 2.0 models, generate executable X-Klaim code using tuple space communication, and deploy directly on ROS-based multi-robot systems.
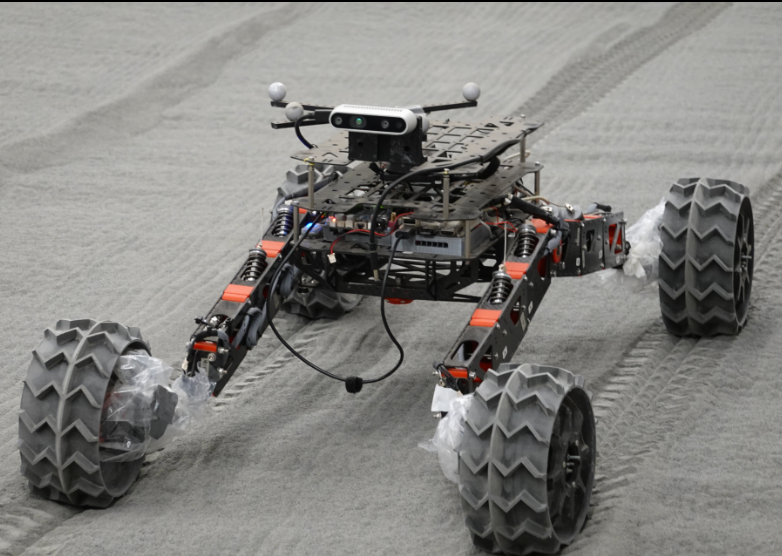
Complete ROS stack for the Archimede rover: URDF, Gazebo simulation, trajectory tracking, SLAM mapping, perception, four-wheel steering kinematics, and teleoperation. Supports ROS1 and ROS2.
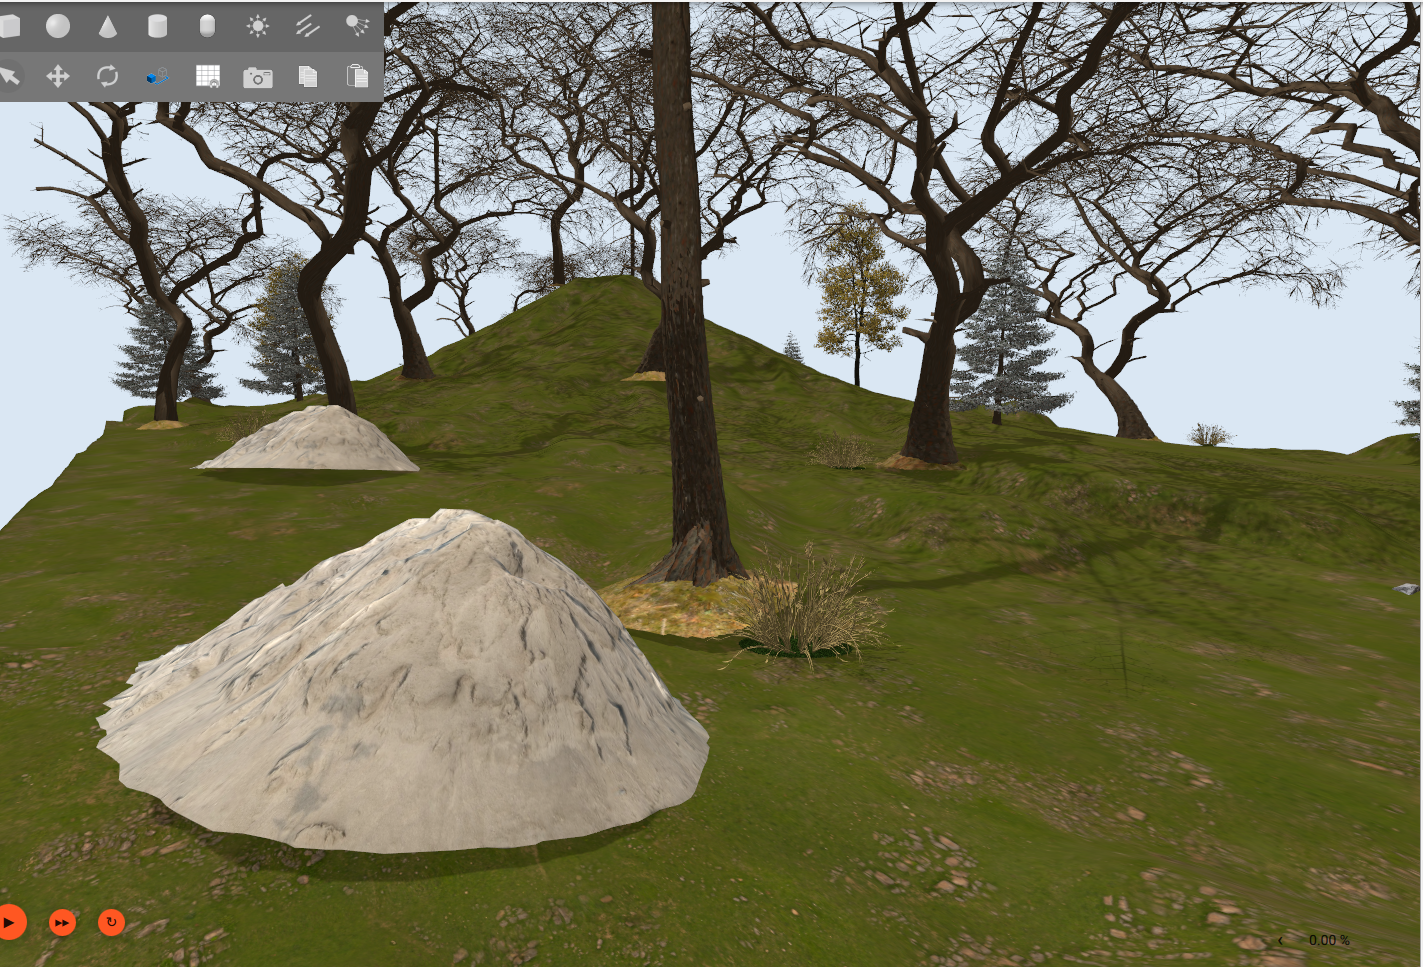
Automated generation of terramechanics-aware simulation environments (IFToMM Italy 2026): converts GeoTIFF DEMs and photorealistic Blender assets into complete Gazebo worlds, with a soil-management system tying each visual material to Bekker parameters for appearance-physics consistency. Demonstrated with the Archimede rover on lunar and forest terrains.
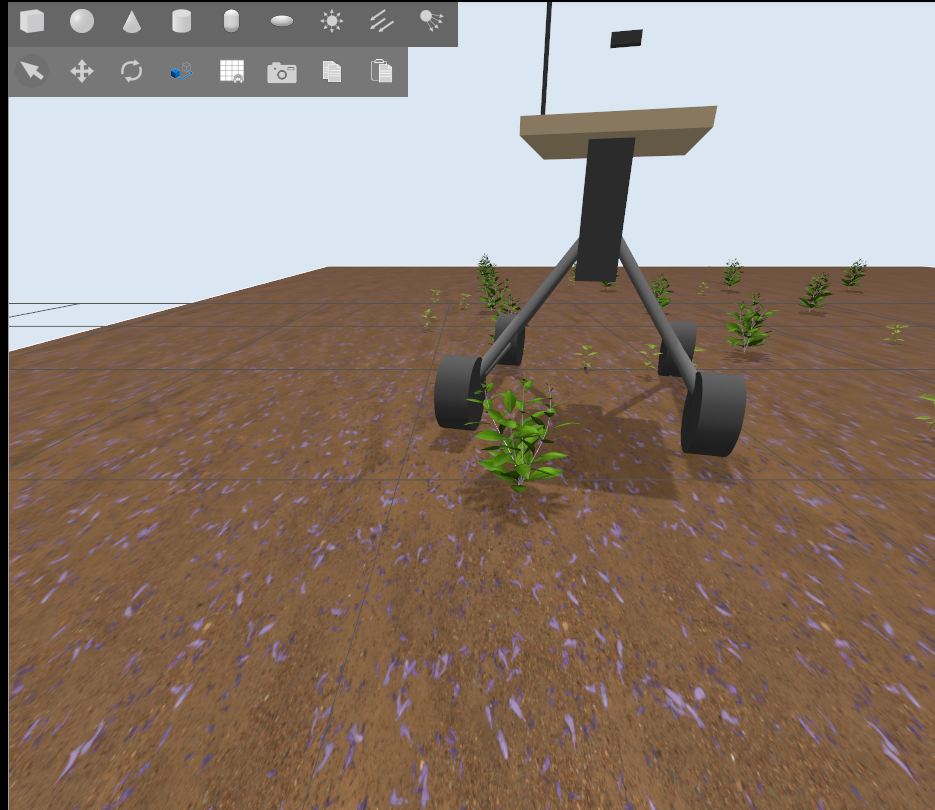
Open-source, containerised ROS2 Jazzy stack for autonomous agricultural robotics. Drivers and orchestration for the Sowbot platform with RTK-GNSS localisation, ESP32-based hardware control, and Gazebo multi-row mission simulation.
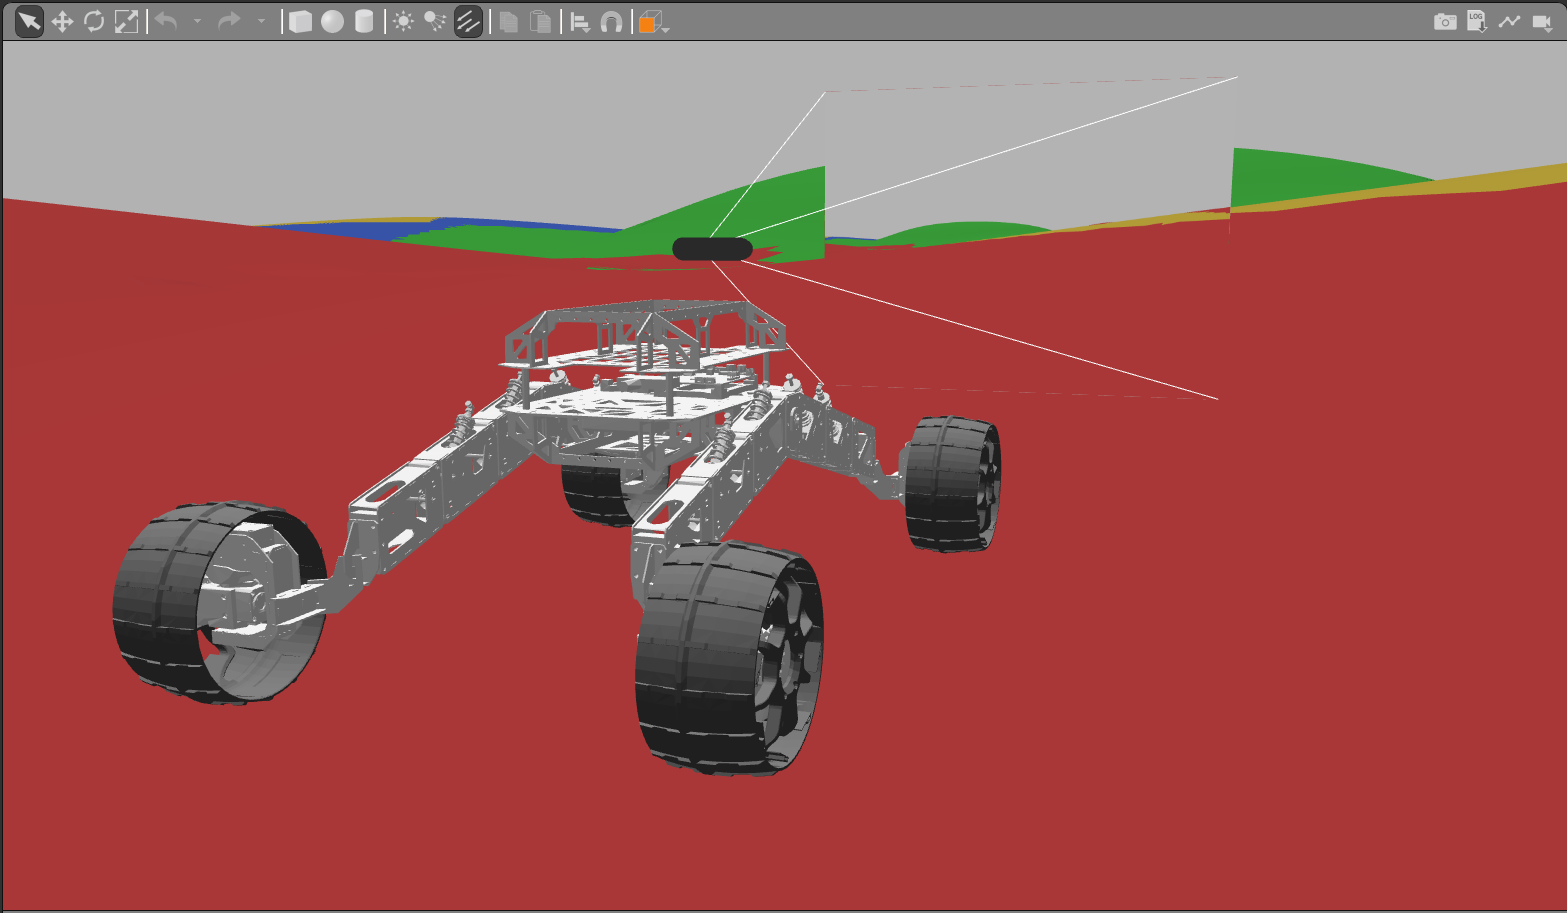
Gazebo Sim physics plugin that simulates soil-wheel interactions (terramechanics) for a four-wheel rover. Computes wheel sinkage, traction forces, and driving torques based on Bekker-Wong soil mechanics theory.
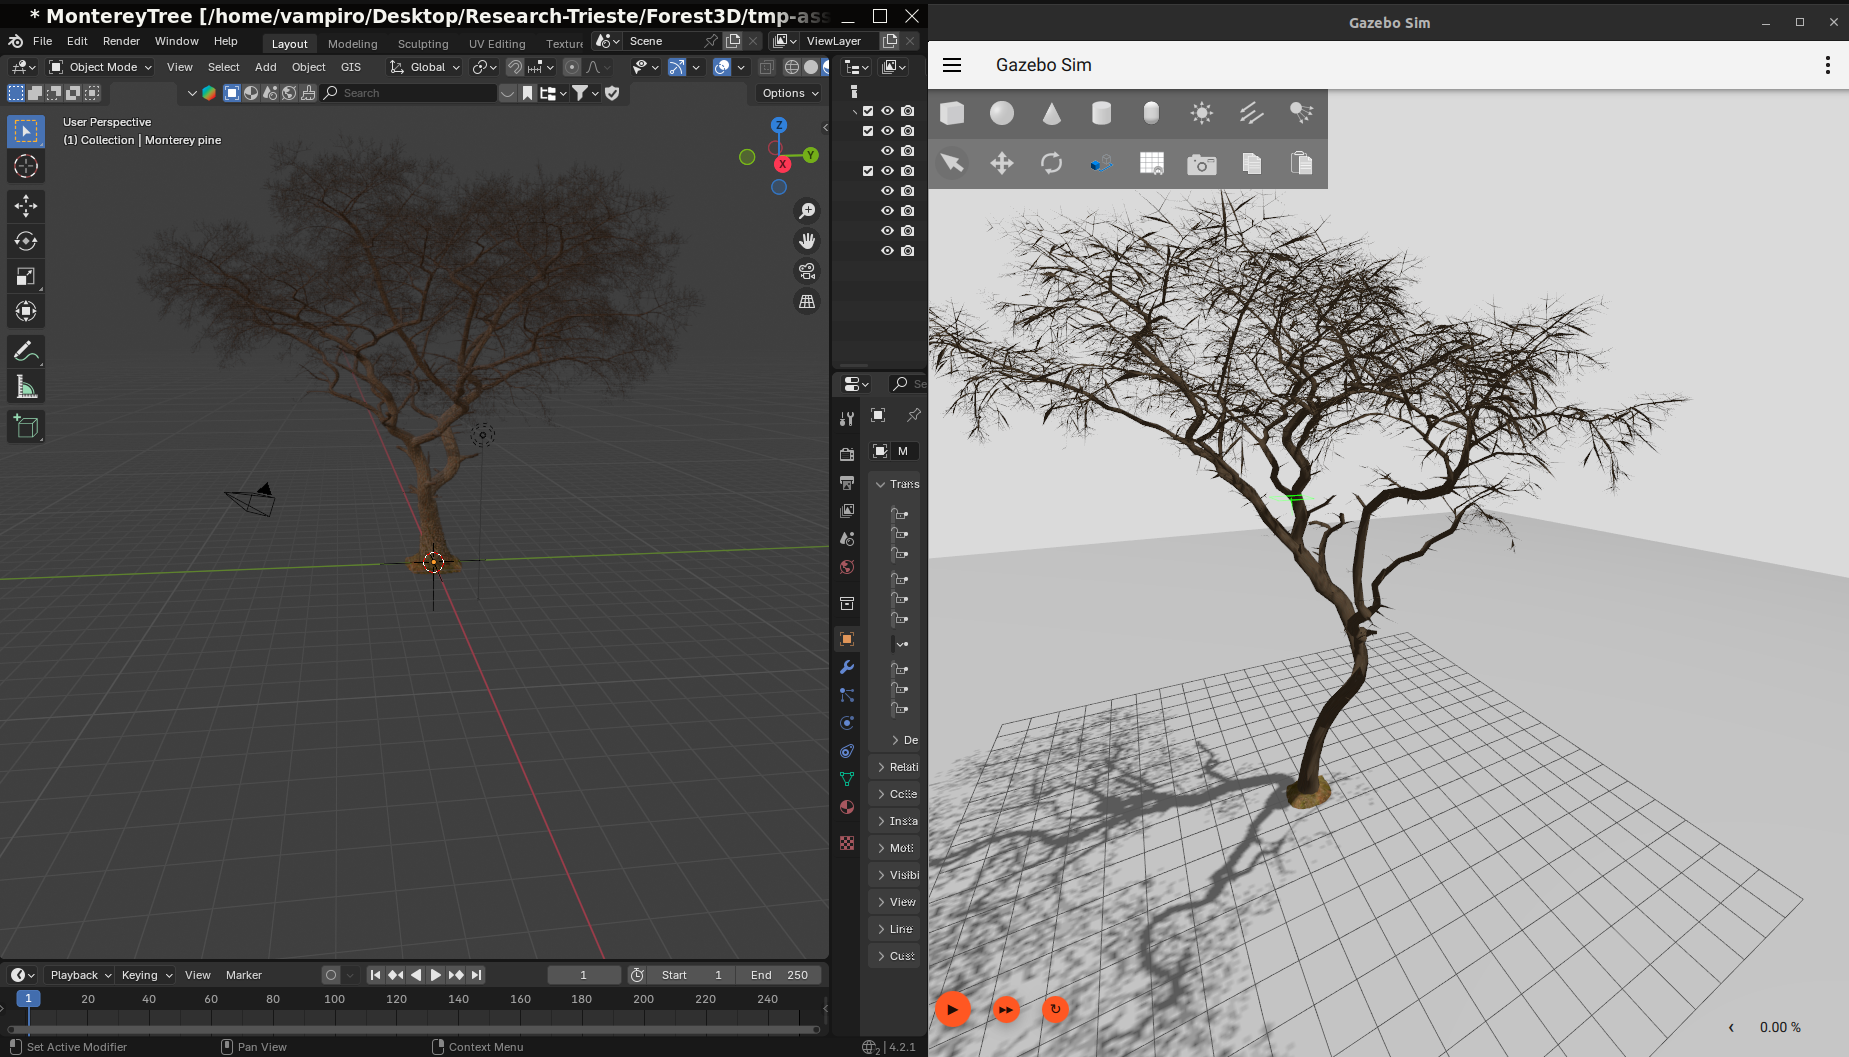
Portable Gazebo SDF bundler. Packs a .sdf world or model and all its assets (meshes, PBR textures, models, plugins) into a single self-executable .sdfz file. One file to share, one command to run: no workspace setup, no path configuration.
An advanced industrial-grade retrofit that transforms a standard household washing machine into a fully programmable, smart appliance powered by an ESP32 microcontroller. The system integrates real-time sensor feedback, high-voltage peripheral control, and Modbus RTU communication to manage complex wash cycles autonomously.
Internal ERP-style platform for NEXANEON: material tracking, stock management, employee presence, client management, and automated business documents (quotes, invoices, delivery notes).

Fitness competition platform for Morocco. Browse and discover competitions, with athlete portals, live scores, rankings, and real-time leaderboards on competition day. Powered by NEXANEON.